One collector for two game-piece geometries
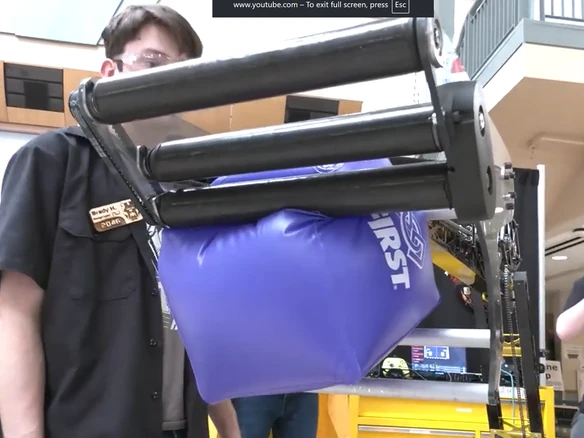
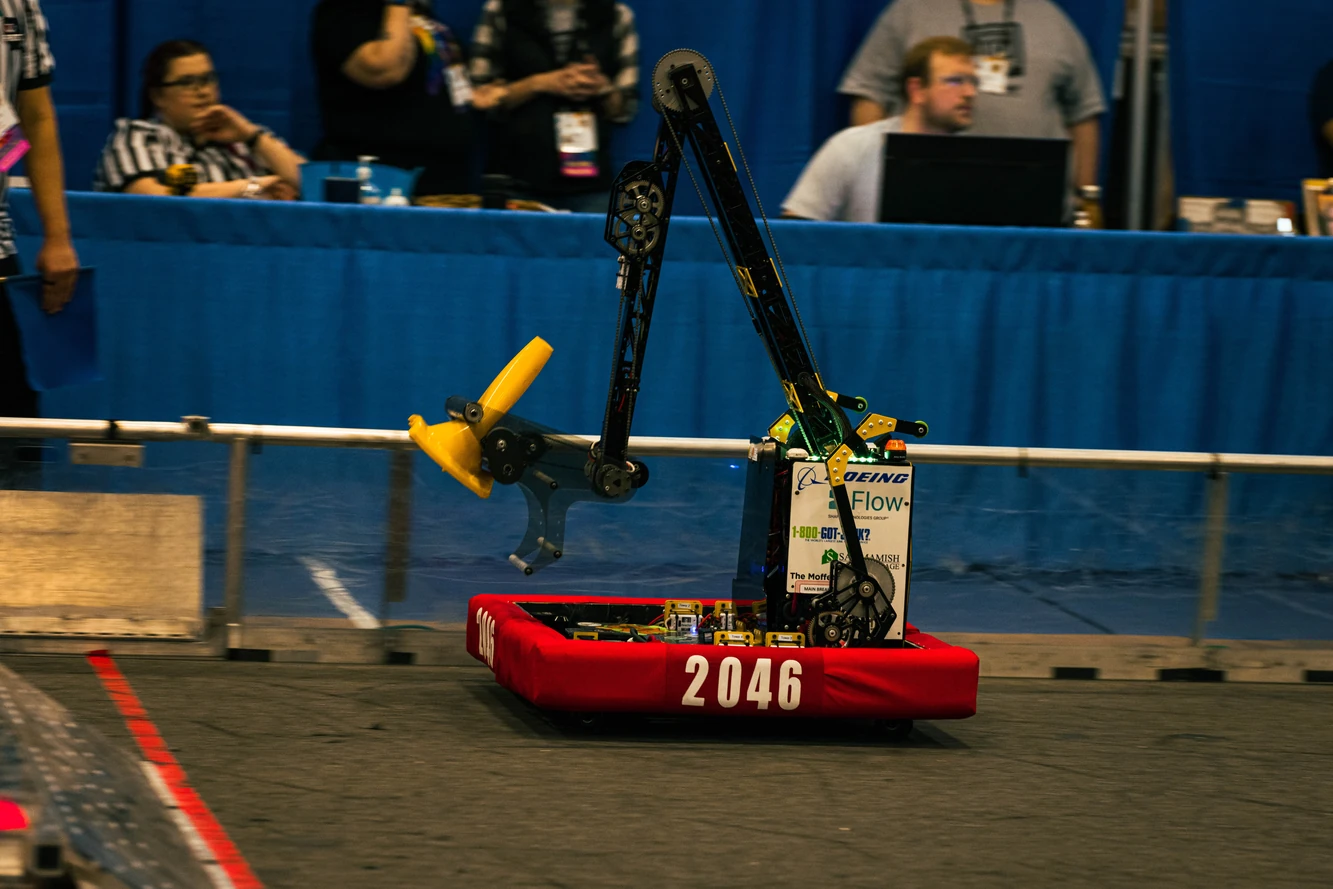
The 2023 CHARGED UP robot needed to collect inflatable cubes and upright compliant cones. The new collector also needed to improve on the previous ground intake and place pieces onto the scoring grid.
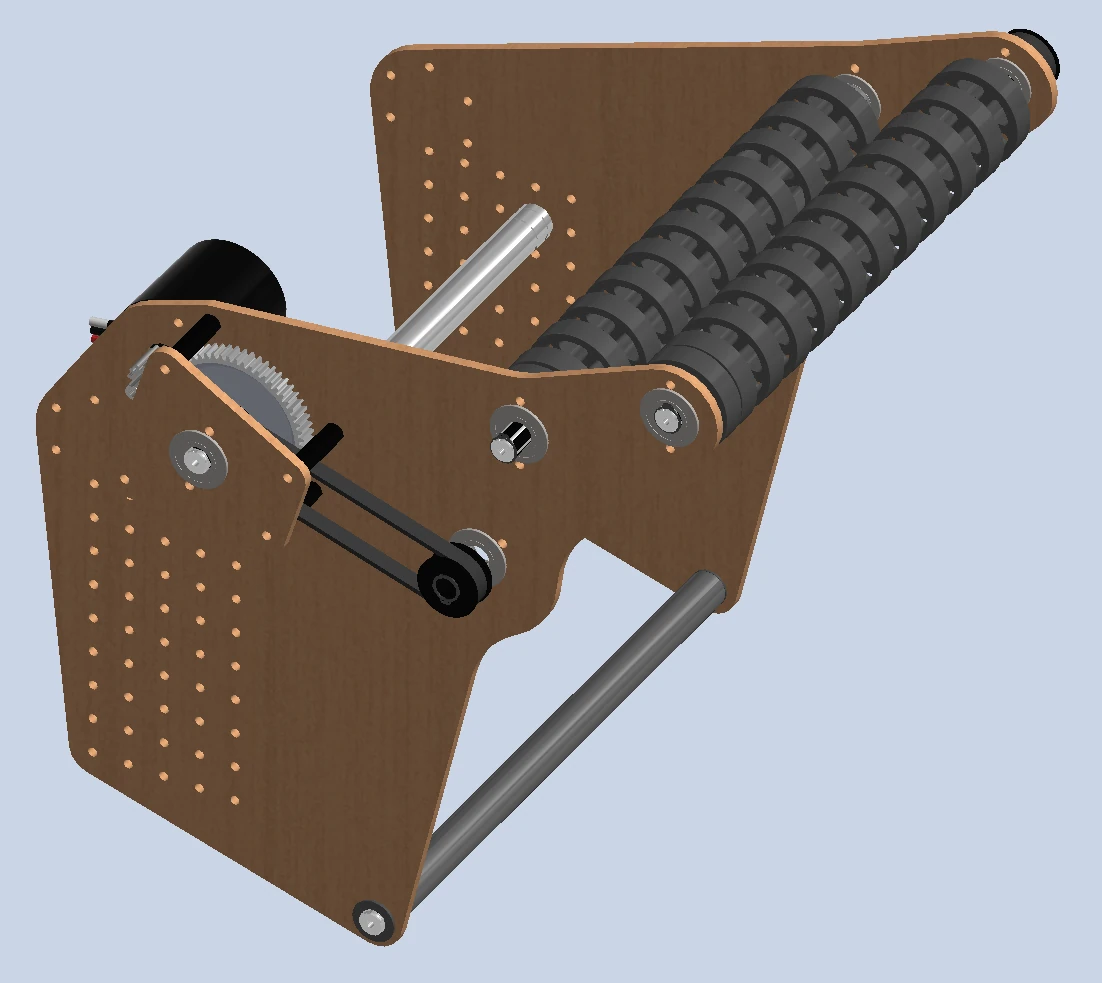
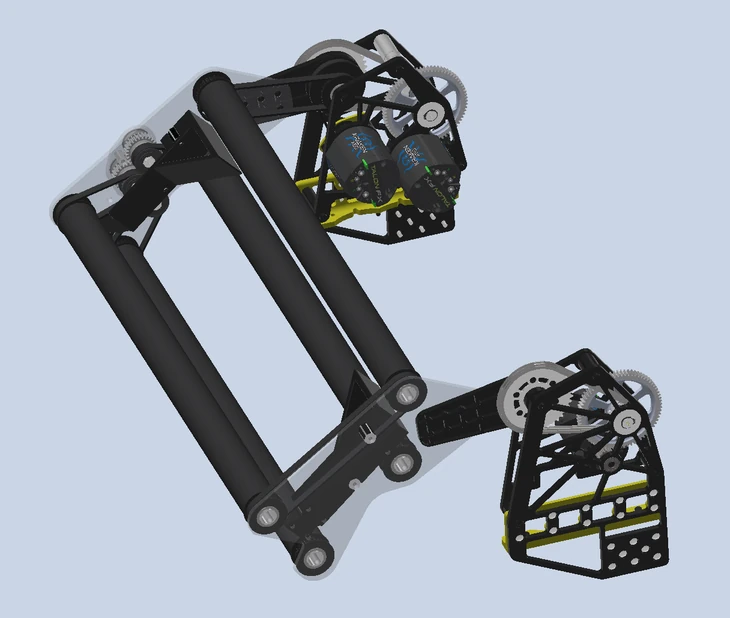
I designed the collector from its initial concept through the complete assembly geometry in Autodesk Inventor.
Adapting the roller arrangement
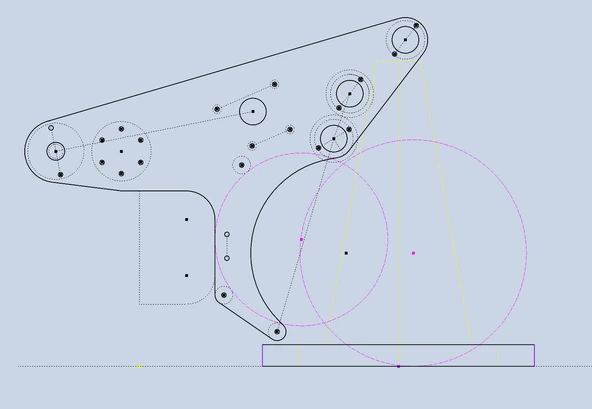
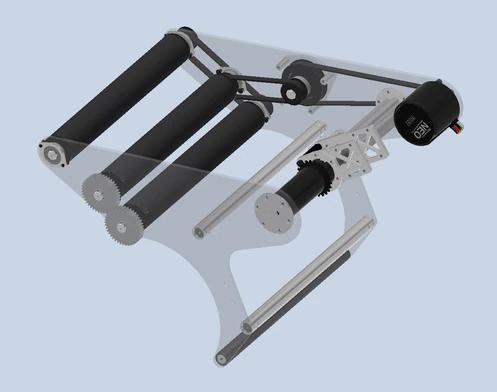
I adapted a two-offset-roller cone concept and added a lower roller to create a universal three-roller intake. During ground pickup, the mechanism referenced against the robot bumper to establish a stable collection position.
Testing the interaction with the cone
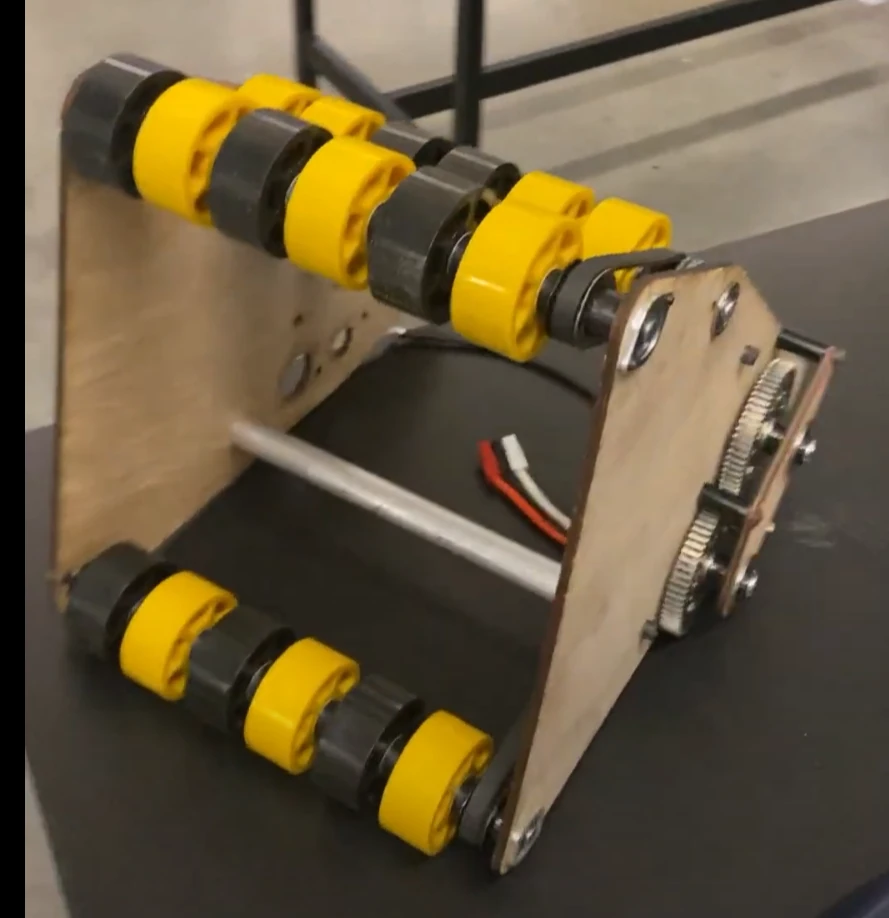
I laser-cut the first side plates from wood to test the geometry. Physical testing showed that the front roller needed to move upward so the rear roller could engage the cone properly. I revised the CAD before final fabrication.
That test changed a major geometry decision early in the process. It also showed me the value of testing the interaction between a mechanism and a compliant game piece, where the behavior of the physical parts was difficult to judge from CAD alone.