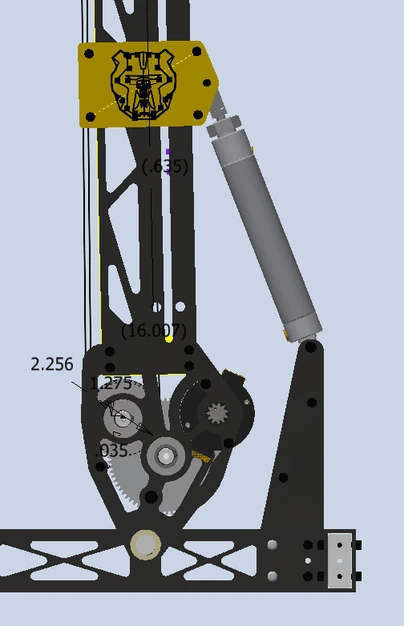
Producing arm motion with a fixed actuator
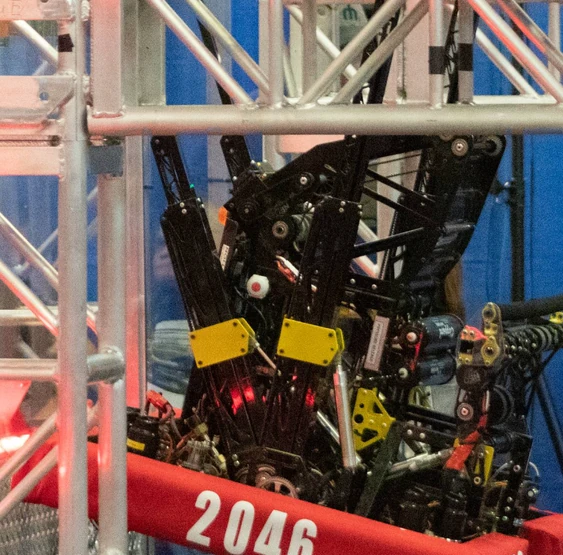
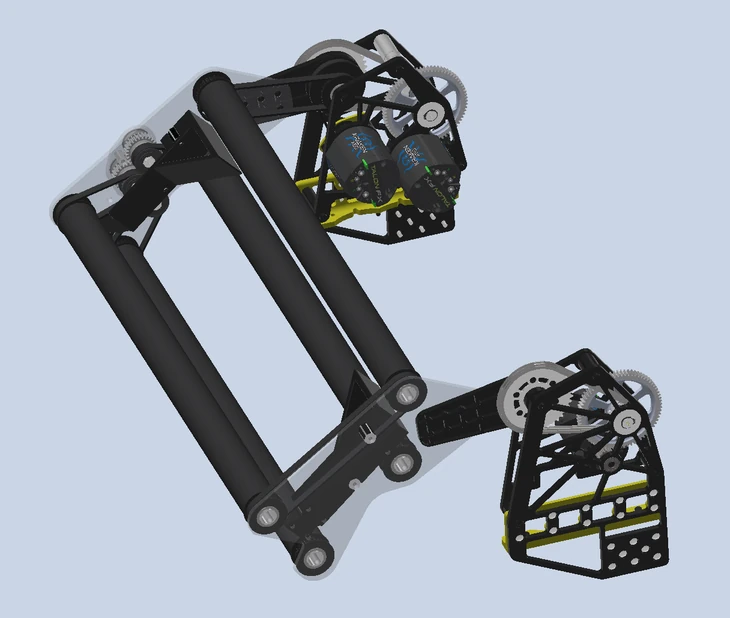
The 2022 RAPID REACT climber needed to rotate its arms within a crowded robot and a short build-season schedule. The robot already carried a compressor, valves, and pneumatic hardware for another mechanism. Reusing that infrastructure avoided the space and development time needed for an additional motor and gearbox.
Translating stroke into rotation
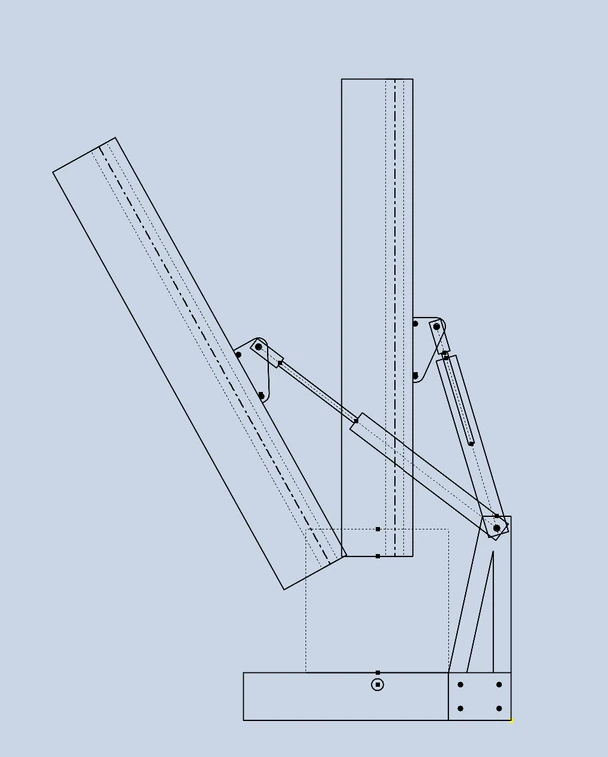
I began with a specified pneumatic cylinder and a target arm rotation. My responsibility was the mounting geometry, support plates, and clamp interface connecting the cylinders to the climber arms.
In CAD, I positioned the cylinder attachment points so the available stroke produced the required rotation while keeping the actuator and mounting hardware within the available space.
Integration and lessons
The mechanism integrated into the climber and provided the required arm actuation during the 2022 season. This was my first mechanism-design responsibility on FRC. It taught me to translate an actuator specification and a motion target into workable geometry, which became a foundation for the larger mechanisms I owned in later seasons.