Supporting a moving articulated arm
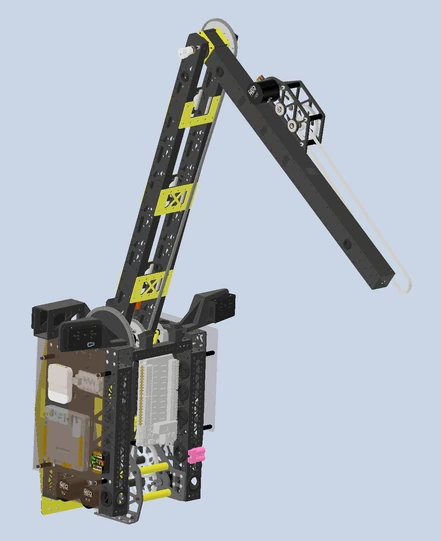
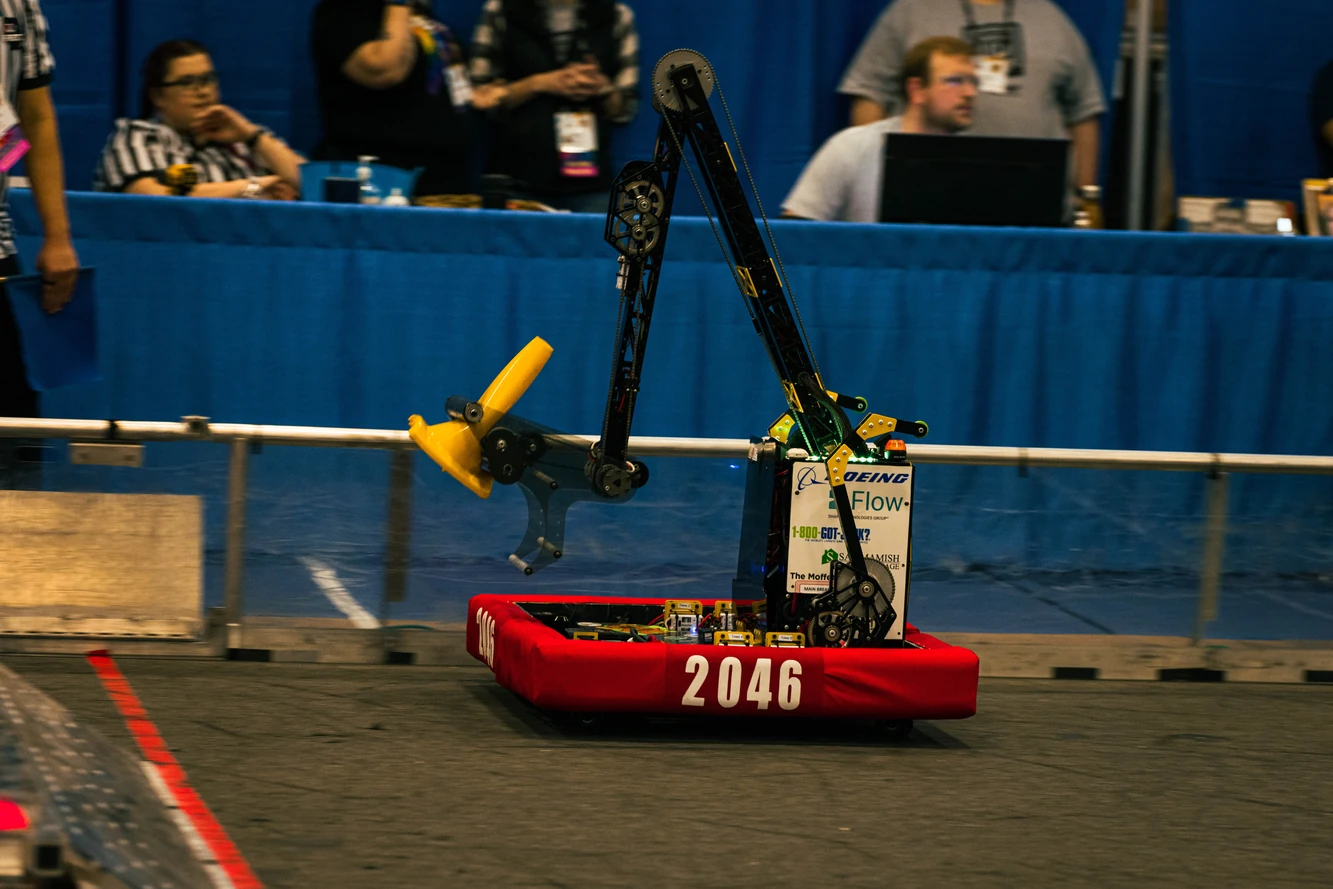
The 2023 CHARGED UP robot used an articulated scoring arm approximately six feet long. The shoulder and elbow gearboxes needed a lightweight supporting structure with enough stiffness for a fast-moving arm.
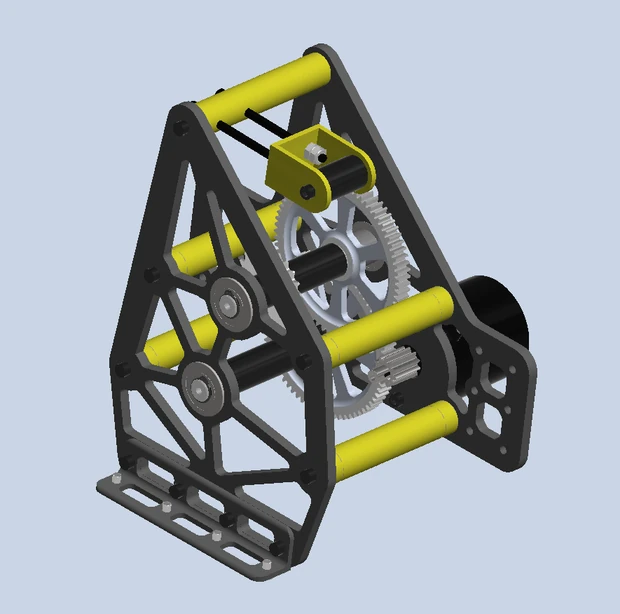
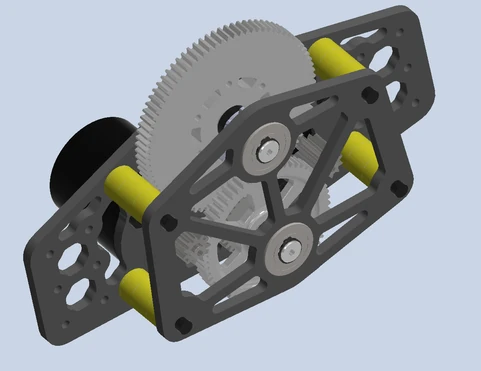
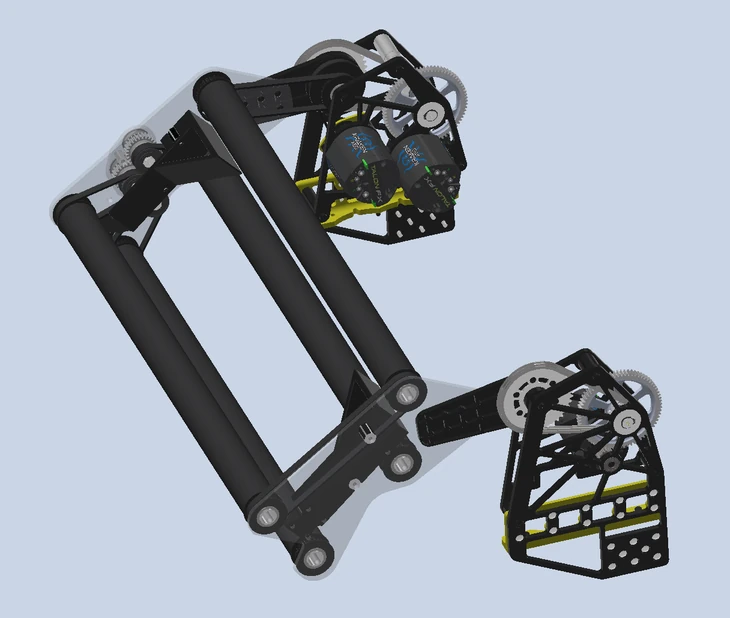
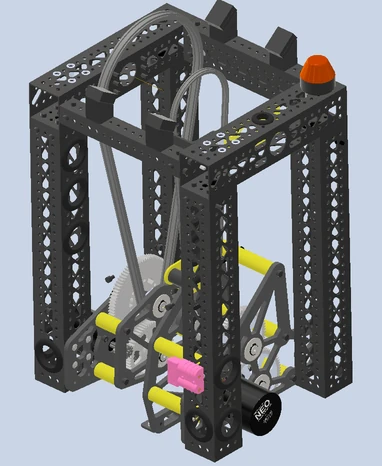
I redesigned and packaged both joint gearboxes, designed the superstructure that secured them to the chassis, and owned the shoulder pivot axle assembly interface. A teammate designed the arm itself. We coordinated the shoulder pivot geometry closely because it connected our work.
Rigidity, weight, and load paths
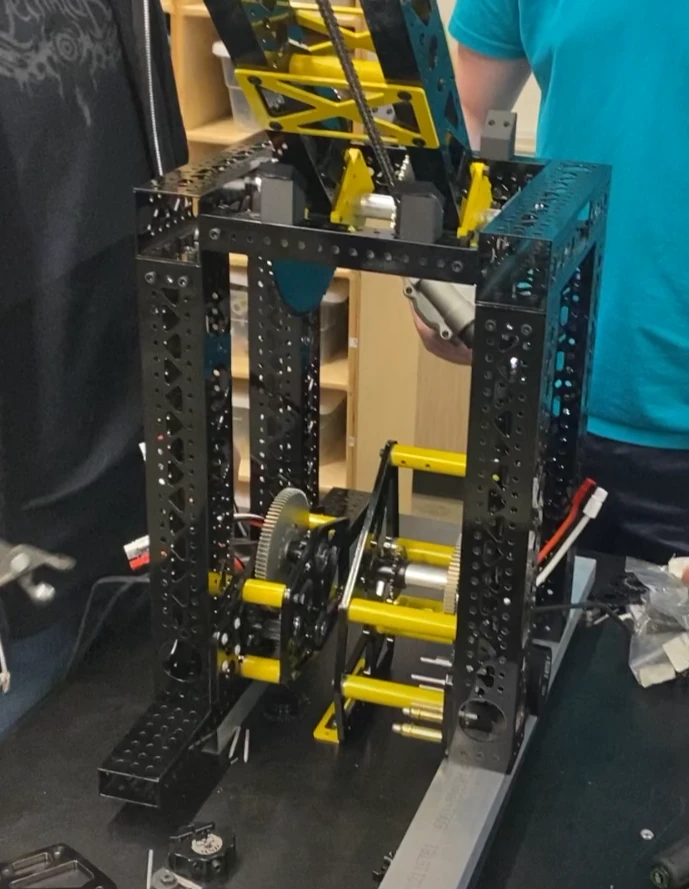
I selected 2 × 2 inch, 1/16 inch wall 6061 aluminum tube for its bending rigidity relative to weight. Triangular pockets removed additional material around the required mounting features while preserving the structure’s load paths.
The gearbox packaging also had to work with the joint geometry and the chassis attachment points. The documented overall reductions were approximately 79:1 at the shoulder and 86:1 at the elbow.
Physical flex drove a structural change
The design process combined CAD, prior design experience, and physical testing. Testing revealed flex in the assembled structure, leading to carbon-fiber braces between the top of the superstructure and the chassis.
The project taught me how to divide responsibility within a tightly coupled mechanical system. Defining and coordinating the shoulder pivot interface let us work in parallel, while physical testing showed where the complete assembly needed reinforcement.